MCP server · Developer tools
TopicForge MCP server
by yaniswav
Lets your AI look at a ROS 2 robot's topics, nodes, recordings and network settings, without ever changing anything.
TopicForge is a helper that lets your AI assistant look inside a ROS 2 robot system. It can list topics, peek at messages, read recording files and spot network setting clashes. It is made for robotics developers and engineers who want answers about a robot without any risk of the AI touching or commanding it.
What is an MCP server? The 30-second version
On its own, your AI can only chat. An MCP server is a small helper program that gives your AI a new skill or a connection to another system. Here, TopicForge connects your AI to a ROS 2 robot and its underlying DDS network layer, so the AI can look things up for you when you ask. It is read-only by design, so it can inspect but never send commands or publish to the robot.
What this MCP server does
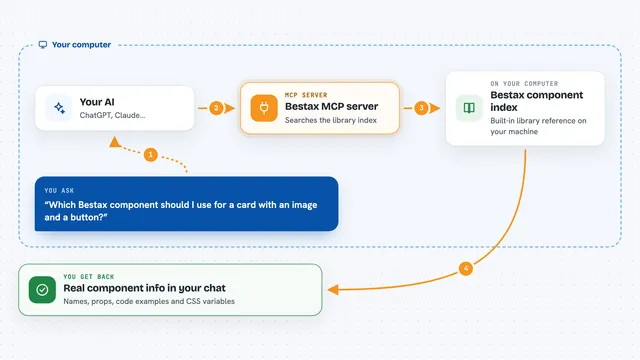
You ask your AI a question about a robot, like which topics exist or why a node is not getting data. The AI passes that question to TopicForge. TopicForge then talks to the robot's ROS 2 tools or to the DDS network layer, or reads a recording file if you point it at one. It collects the facts, such as topic names, message types, node details, network settings or recording summaries. Then it hands a clean, structured answer back to your AI, which explains it to you in the chat.
What you can do with it
- List all topics and nodes on a running ROS 2 system
- Show the message type, publisher and subscriber counts, and settings for one topic
- Peek at recent messages on a topic, up to 50 at a time
- Summarize a recorded bag file (.mcap, .db3 or a rosbag2 folder)
- Spot incompatible network settings between senders and receivers
- List the DDS participants on the network with their vendor and hostname
- Inspect the transform tree and find stale or broken frames
Try asking your AI
- “List the topics on this robot and tell me which ones have no subscribers.”
- “Why is nav_planner not getting any scan data? Check for network setting mismatches.”
- “Summarize the recording at /tmp/demo.mcap and tell me how long it is.”
- “Show me the nodes on the graph and any duplicate names.”
What it gives back to you
You get back clear, structured answers in the chat: lists of topics or nodes, counts, message samples, recording summaries, or a named mismatch like a sender using one setting and a receiver expecting another. Each answer also says whether it came from a real robot or from built-in demo data, and includes a short note if anything was unusual. It never changes anything on the robot, so the results are always observations, not actions.
Before you start
What you need
- Python 3.10 to 3.13 installed
- The topicforge package installed with pip
- An MCP client such as Claude Desktop or Claude Code
- A ROS 2 setup or a DDS network if you want live data; otherwise it runs on built-in demo data
Good to know
It is read-only and cannot publish or command a robot, but it can read robot data and recording files, so only point it at systems and files you are allowed to inspect.
Install it with your AI
Add TopicForge MCP server to your AI, no technical skills needed
You don't install anything by hand. You copy one prompt, paste it into an AI that can work on your computer, and it checks, installs and connects the server for you, asking you when it needs something.
Sign in to get the install prompt
Members get a ready-made prompt that lets the Claude desktop app check TopicForge MCP server, install it and connect it for them, step by step. You don't need any technical skills: you copy, paste and answer a few questions. Your connected AI can also find and install any of the 4,361 MCP servers here for you.
Who it's for
ROS 2 developers, robotics engineers and teams who need to inspect a robot or its network safely without any risk of the AI sending commands.